Four product lines across the full evaluation chain
Edge AI inference and on-board computing for all hardware products are deployed on the NVIDIA Jetson platform. R-Eval is live; R-Box and R-ORV have completed prototype validation.
A test carrier built to be crashed
Existing research platforms: ≤10 km/h, flat indoor floors, single-robot, ¥75–150K per unit — lab assets too precious to crash. The R-ORV inverts every parameter: 304×215 mm footprint, 60 km/h top speed, ≤¥30K per unit, expendable — designed for adversarial testing, fault injection, and multi-vehicle scenarios.
| Dimensions | 304 × 215 mm |
|---|---|
| Top speed | 60 km/h straight-line (field-tested, 2026) |
| Track average | 35 km/h (unpaved track, measured) |
| Unit cost | ≤ ¥30K |
| Configuration | High-torque Ackermann-steering 4WD off-road chassis, R-Box mountable |
| Edge computing | NVIDIA Jetson platform for motion-state sensing and power-distribution control |
| Status | Prototype validation complete; batch consistency subject to 60-unit small-batch run |
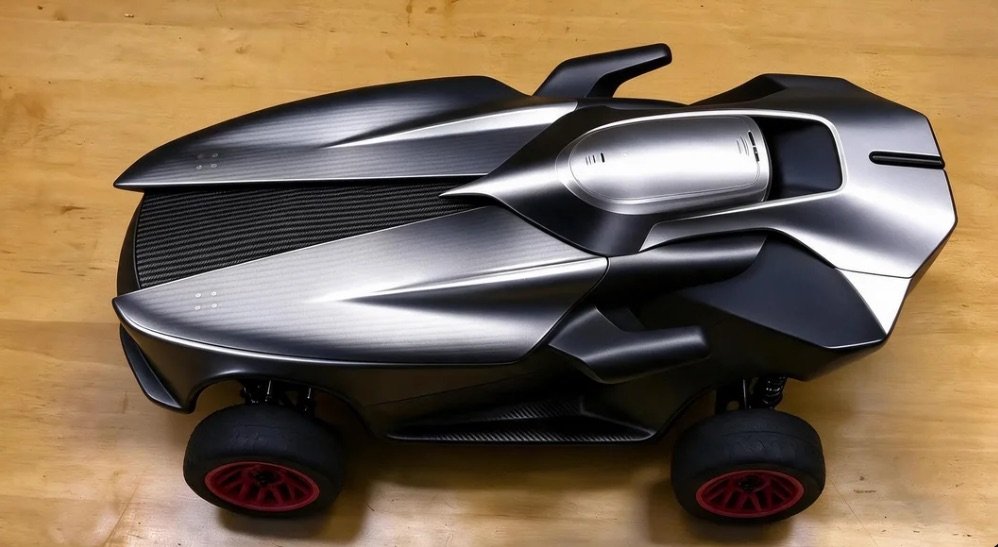
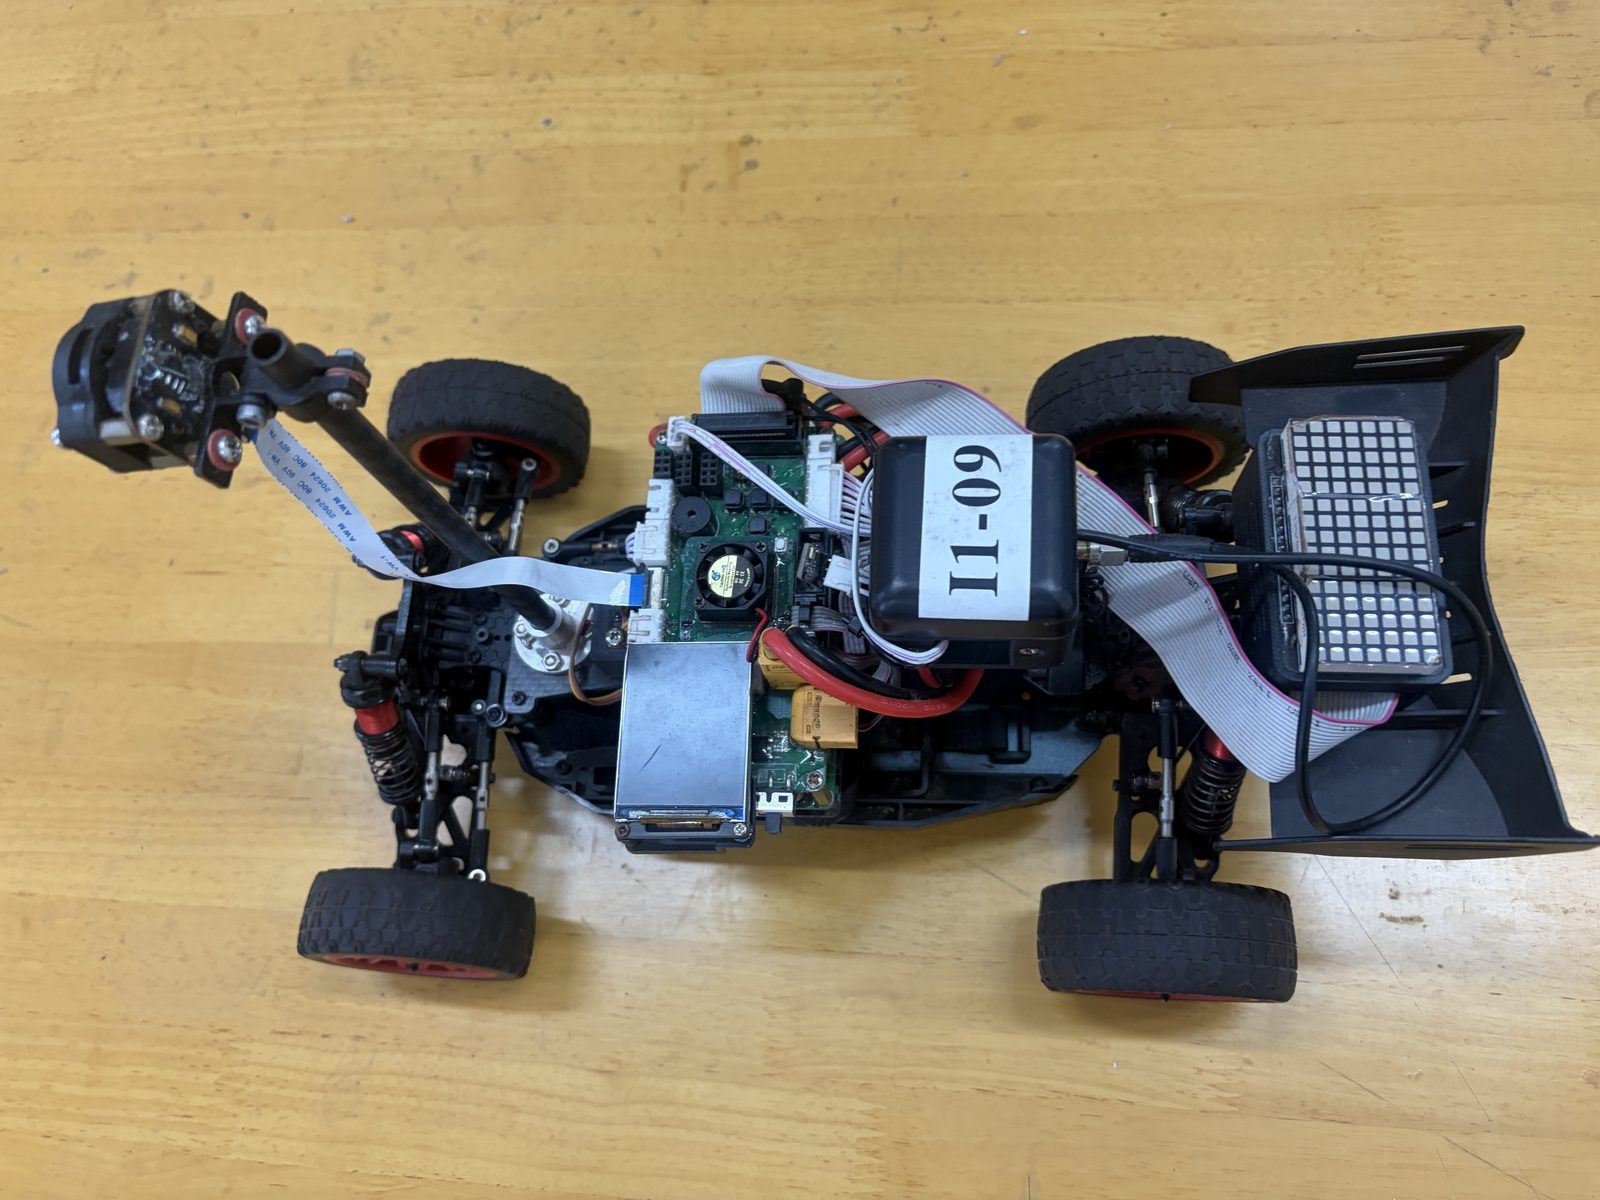
Brand film: real R-ORV field footage + concept (CG) adversarial competition scenes, 92 seconds.
Measurement is evidence
Self-designed vehicle-mounted measurement hardware, with edge capture and preprocessing on the NVIDIA Jetson platform. Five prototypes built and vehicle-validated, with 17+ dimensions of stable capture — capture and evidence retention happen in one step.
17+ dimensions
IMU, vision, CAN bus, coordination link, fault events — multi-source data unified into one store.
Unified time base
Time synchronization maintained under GNSS-denied conditions — an engineering barrier, not an algorithmic one.
Fault injection
Standardized fault scenarios: designed, reproducible, replayable — feeding the RRI / CRI metrics.
Tamper-evident capture
Capture is evidence: evaluation reports become auditable and re-checkable.
| Prototype | 5 units built, vehicle capture chain running |
|---|---|
| Production | Delivery starts after 60-unit small-batch validation (in progress) |
Intelligent evaluation, traceable judgment
Self-designed evaluation software, delivered as SaaS or on-premise, live and running. The pipeline runs end to end: R-Box capture → temporal alignment → event segmentation → metric output. Conclusions are reproducible, auditable, and traceable.
Demo requires a Kimi account sign-in; the workspace includes a public competition dashboard.
From capture to conclusion in four steps
17+ dimensions captured on a unified time base, tamper-evident
Multi-source, heterogeneous data aligned onto one time base
Automatic slicing by fault event and task phase — faster attribution
RRI / CRI quantified scoring — reproducible, auditable conclusions
One platform, three views
Evaluation workspace
Import R-Box capture data, run temporal alignment, event segmentation, and metric computation. Projects organized by competition and task, with results archived and traceable.
Traceable judgment
Every judgment maps back to raw data segments and timestamps: scores can be replayed and reviewed, disputes arbitrated — same logic for competition judging and delivery acceptance.
Public dashboard
During competitions: rankings, task completion, and key-event timelines displayed publicly — visible evaluation becomes shareable material.
The system is running — the interface is the proof
Actual screenshots from the R-Eval adjudication system: the two core views, overview and scoring.
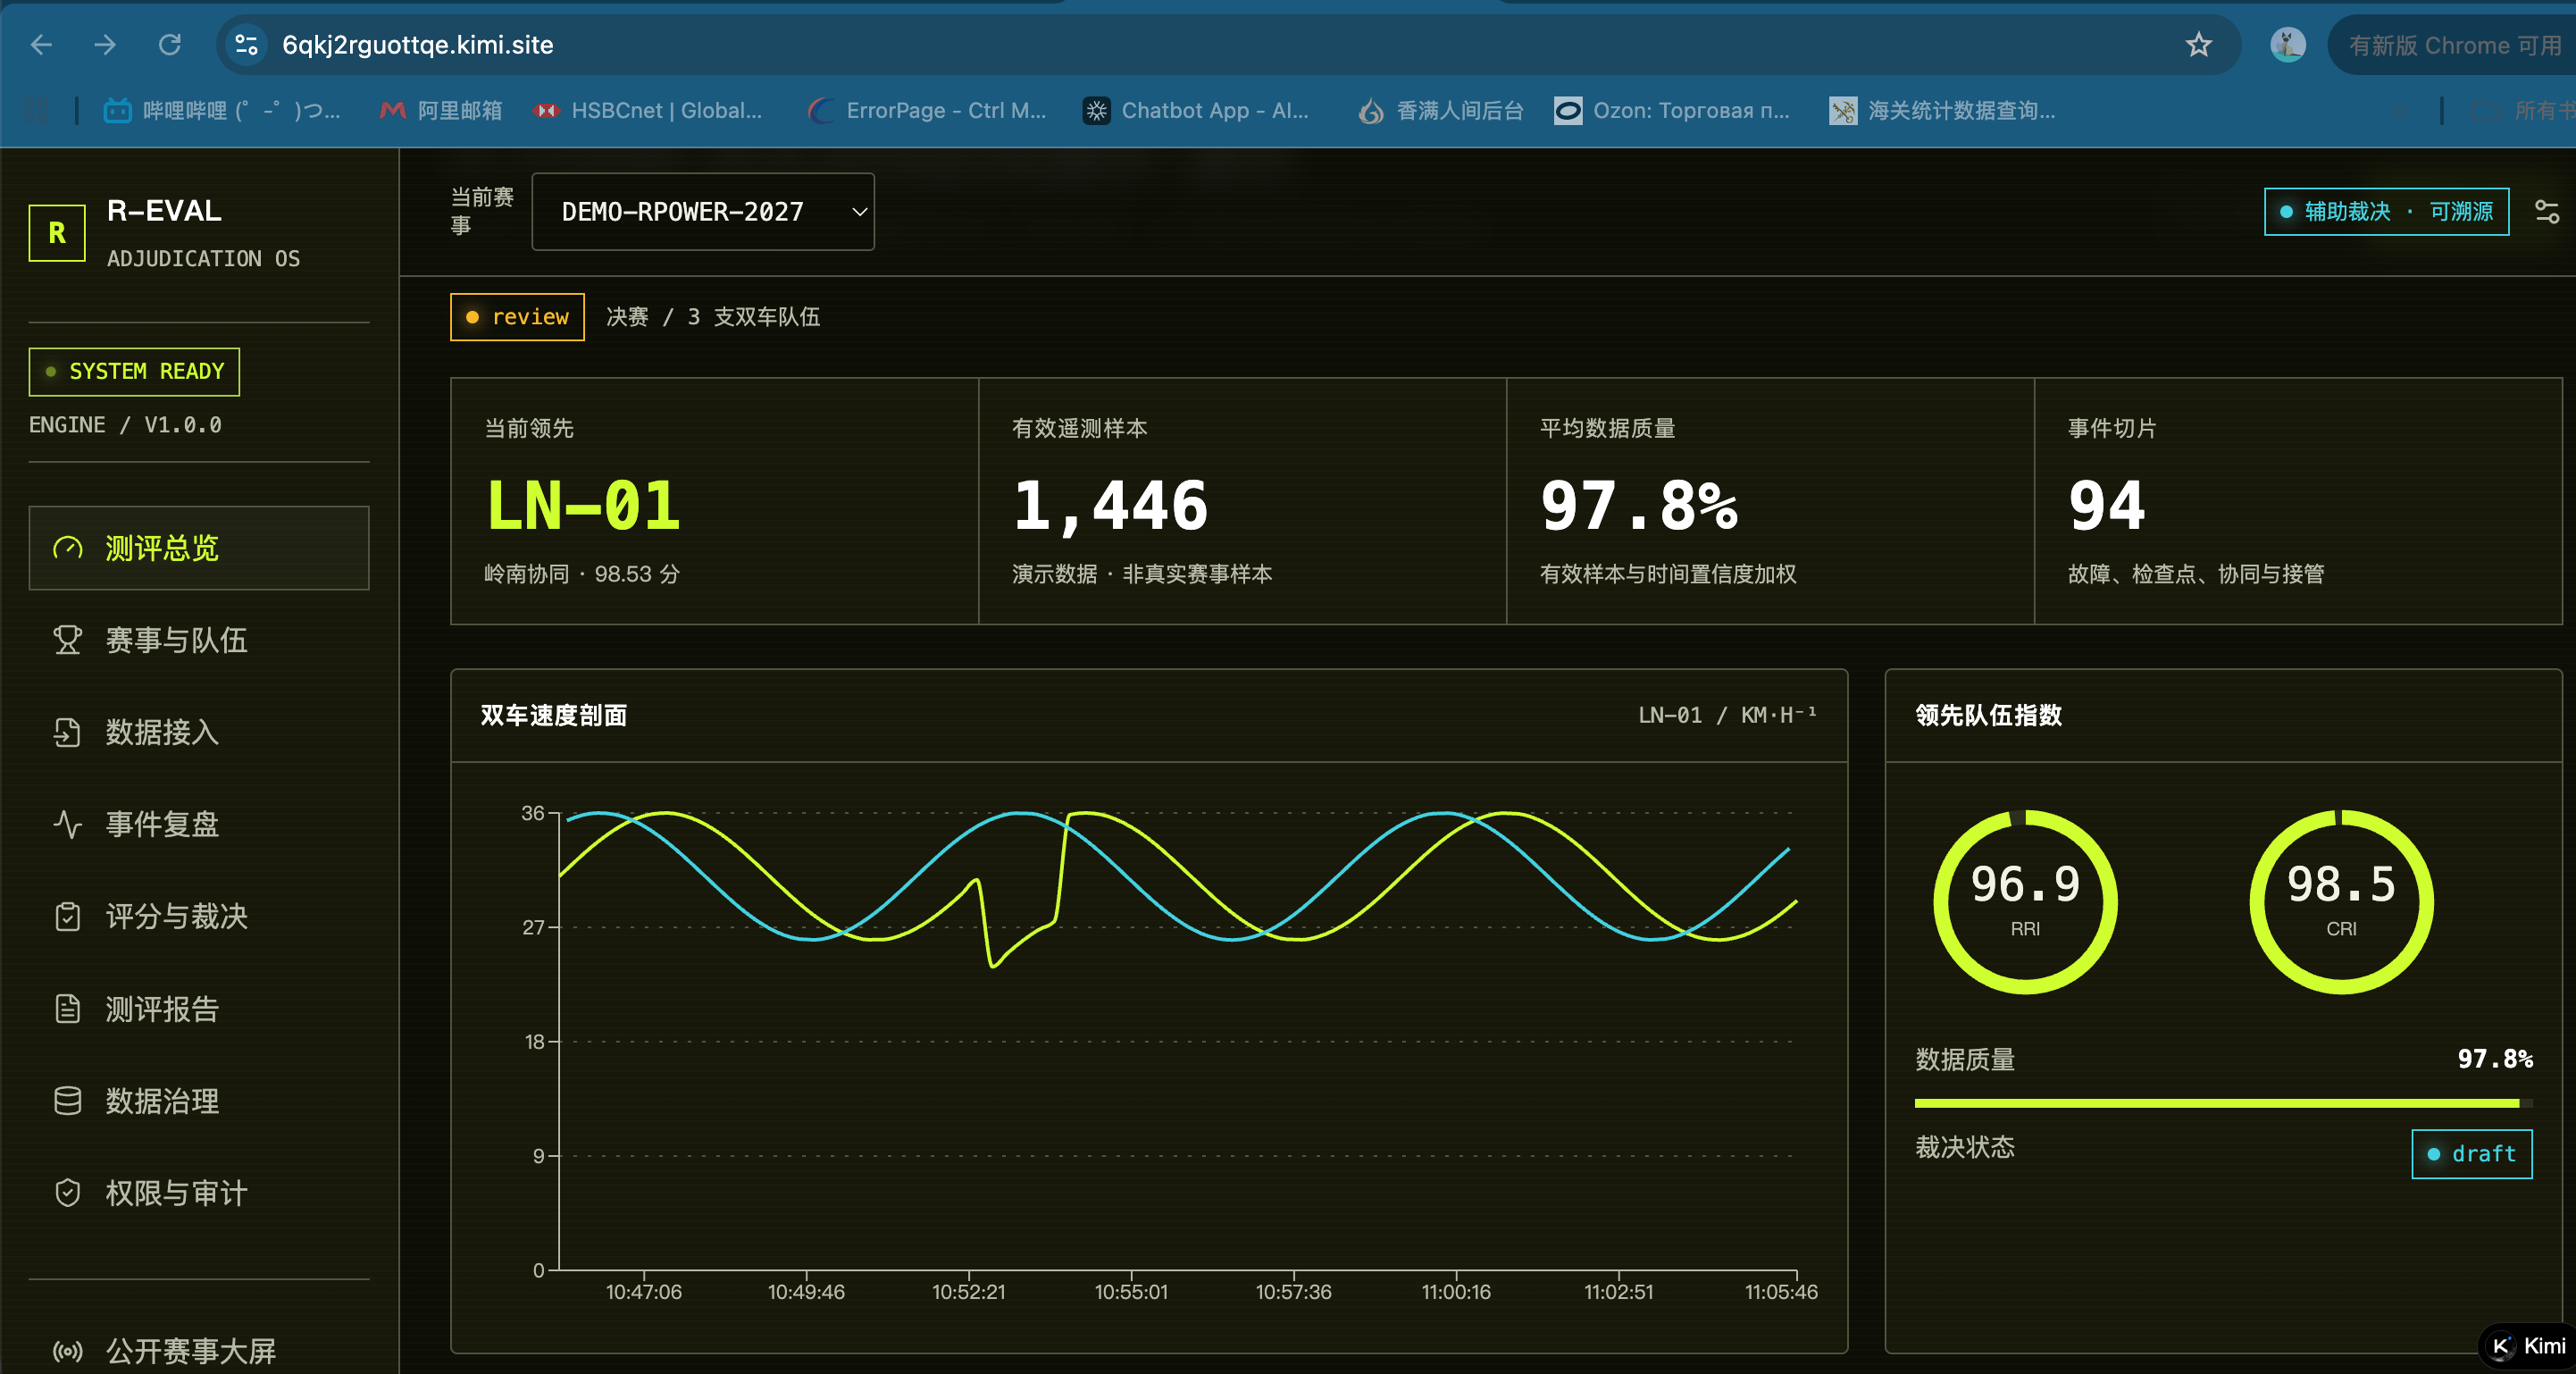
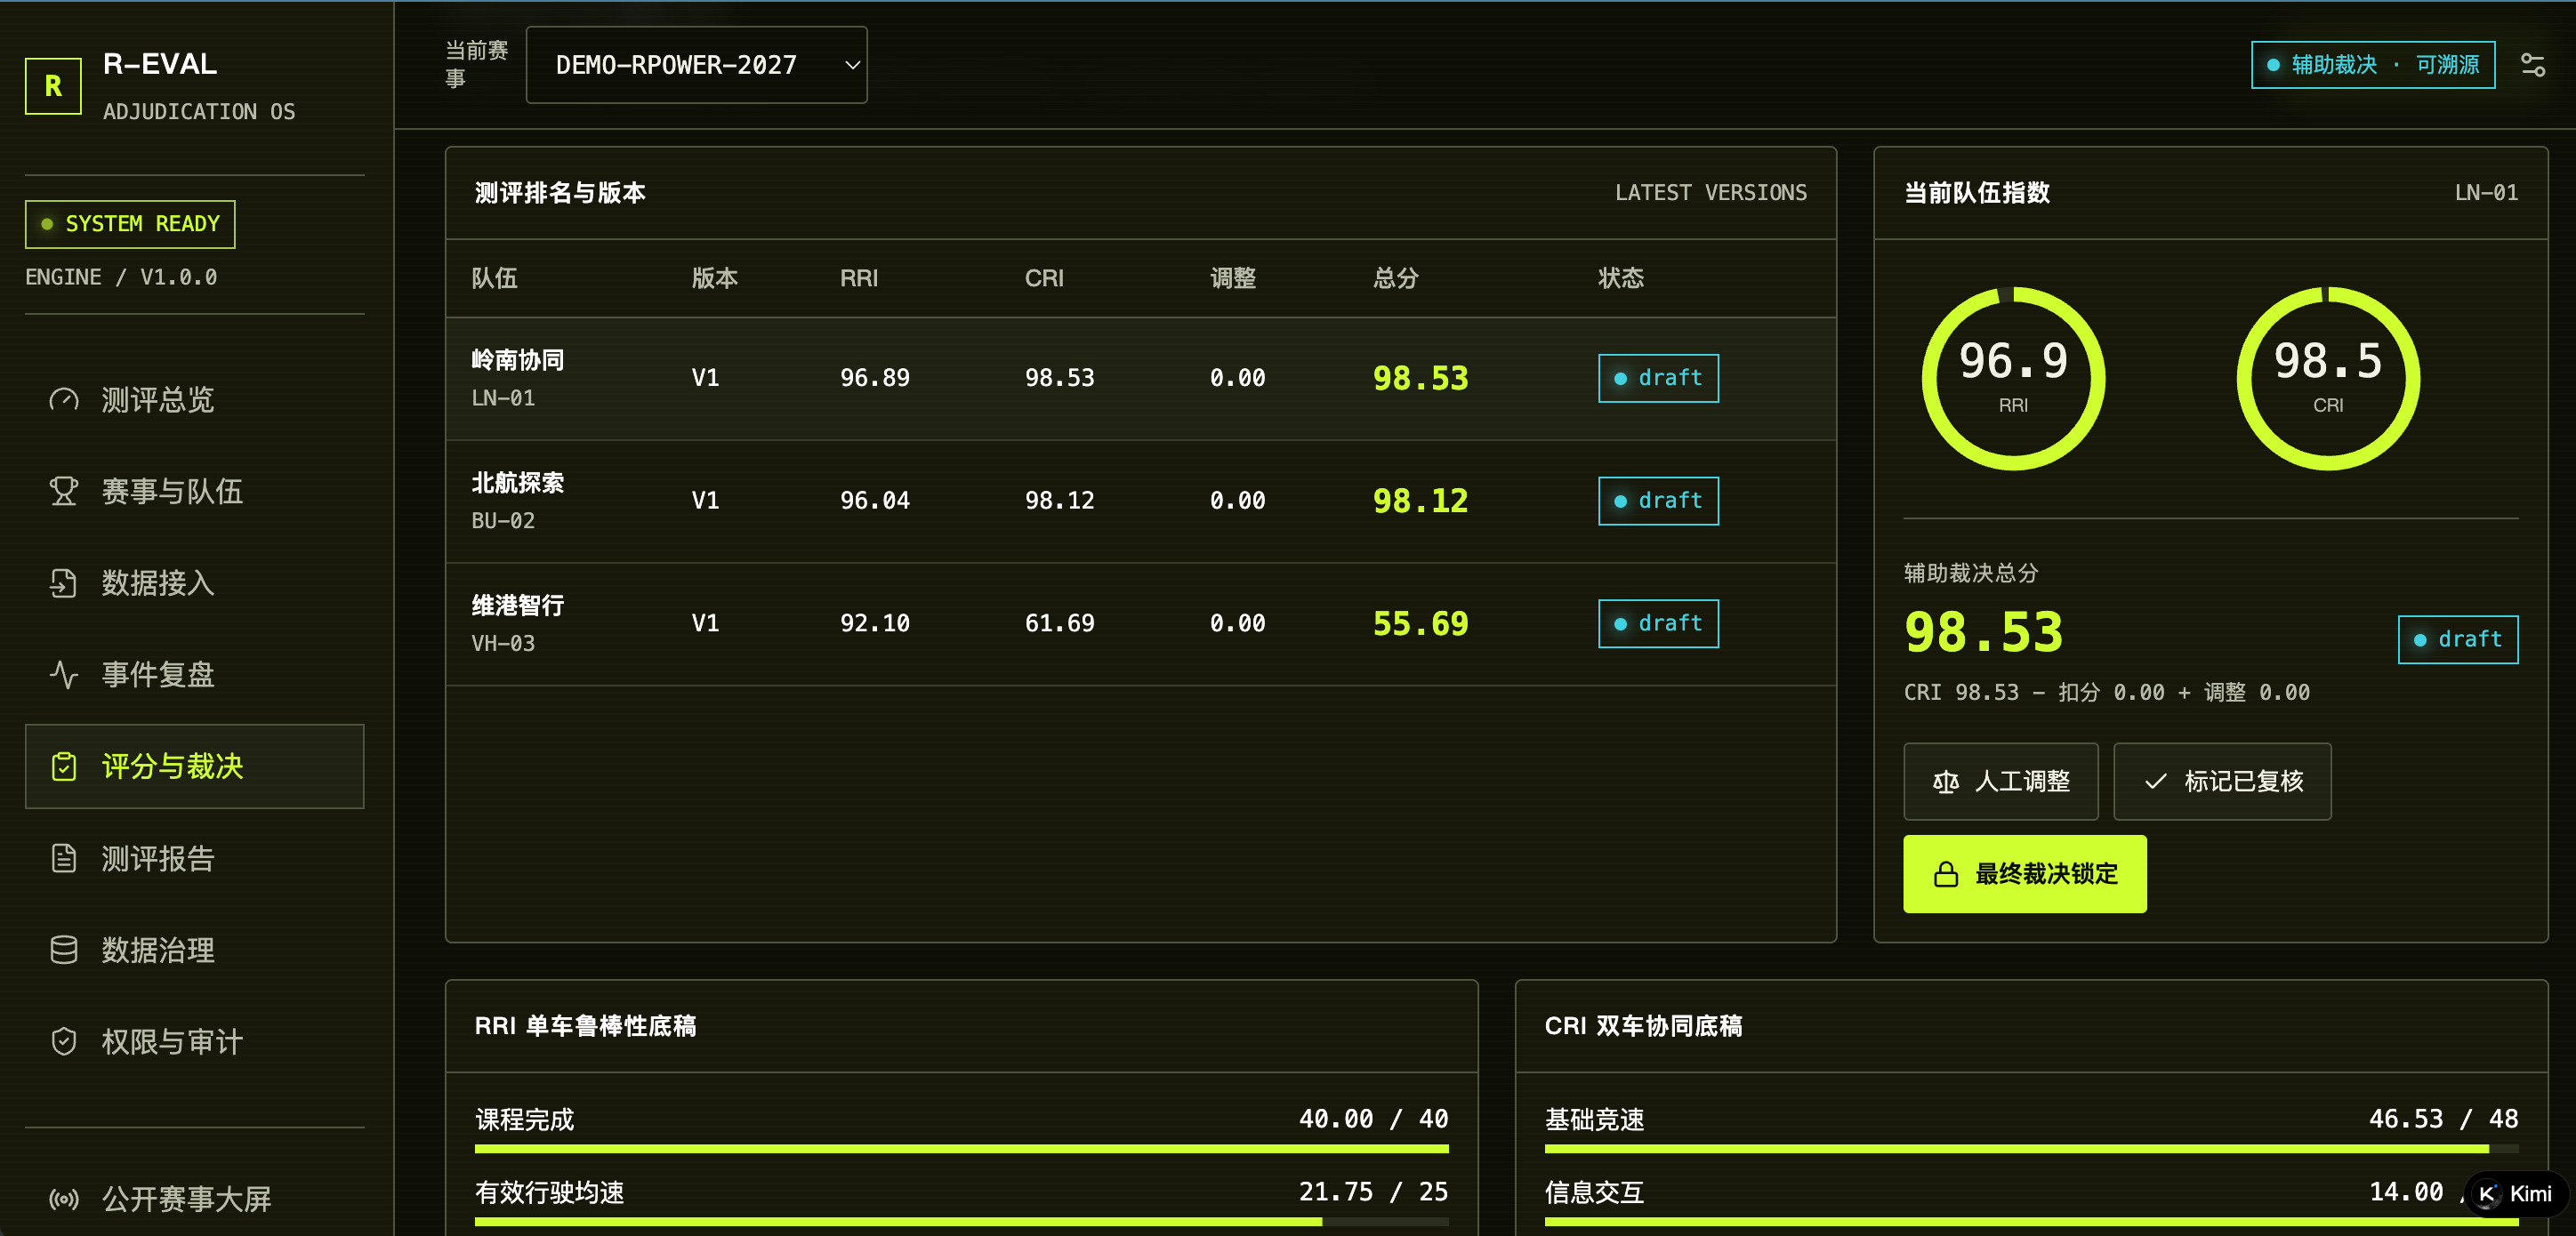
RRI / CRI: reliability without adjectives
RRI · Robot Reliability Index
Quantified scoring of single-robot reliability in defined scenarios, driven by fault-injection results and task-process data. Same vehicle, new data, the score speaks.
CRI · Coordination Reliability Index
For multi-vehicle coordination: formation keeping, task-allocation success rate, and link stability quantified in one index — coordination becomes horizontally comparable.
Two delivery options, status stated as-is
| Delivery | SaaS subscription / on-premise (data stays on-site) |
|---|---|
| Status | Live; pipeline running end to end |
| Data input | R-Box capture (standard-format import supported) |
| Live demo | 6qkj2rguottqe.kimi.site (Kimi account required) |
R-SIM simulation platform · dual-vehicle university research kit
R-SIM simulation platform (planned)
A simulation environment closed-looped with R-Box / R-Eval field data: real fault data feeds back to refine the model, narrowing the sim-to-real gap. Beta in Q4 2027.
Dual-vehicle coordination research kit
For university labs: two carriers + R-Box measurement + R-Eval teaching edition + course experiments — an out-of-the-box multi-agent research platform.